About the project
Motion Gesture Controlled Car
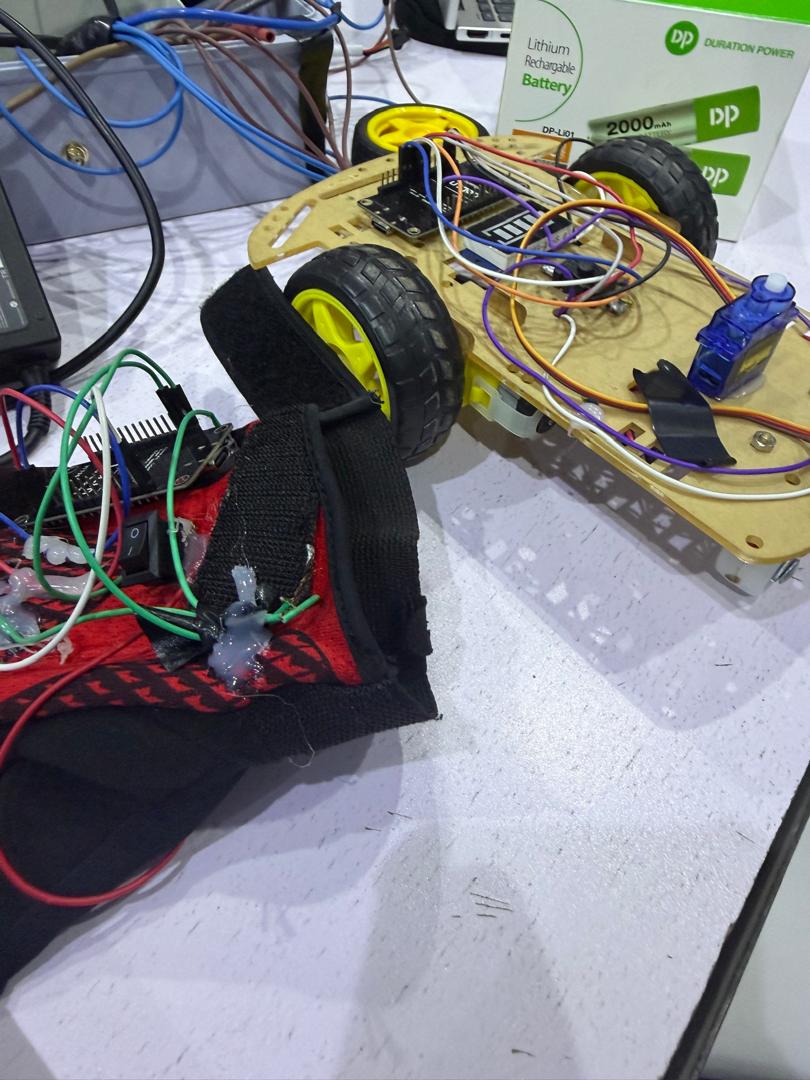
I built a wearable gesture-control system that lets you pilot a robotic vehicle using natural hand movements. It uses an inertial sensor on a glove to track the pitch and roll of my hand. It then transmits that data instantly to the vehicle using a low-latency, peer-to-peer wireless protocol. It's designed to be highly responsive and includes built-in safety features to prevent the car from running away if it loses connection.For this project I made use of a Robot Chasis Car which I assembled myself
Components I made use of
ESP8266 Microcontrollers
MPU6050
L298N Motor Driver
Geared DC Motors
Part of my code
typedef struct {
int forwardTilt;
int sideTilt;
} HandData;
HandData myData;
Results
I successfully engineered a fully custom, low-latency robotic car controlled entirely through hand gestures on a wearable glove. I eliminated network lag by implementing the ESP-NOW protocol for direct, routerless communication, creating a near-instant link between my movements and the vehicle's response. Using an MPU6050 IMU sensor, the system accurately maps raw gravitational data into precise pitch and roll angles to seamlessly dictate steering and speed. To ensure physical stability and operational safety, I applied software-level differential trimming to calibrate the motors alongside a non-blocking watchdog timer that forces an emergency stop if the wireless connection drops.
 Micheal Oluwanifemi OniRobotics Engineer Python
 RAIN